How to read this finding
This table compares types of evidence, not a common performance benchmark. Driverless mileage does not establish general manipulation ability, and an inspectable action plan does not establish reliable full-task completion.
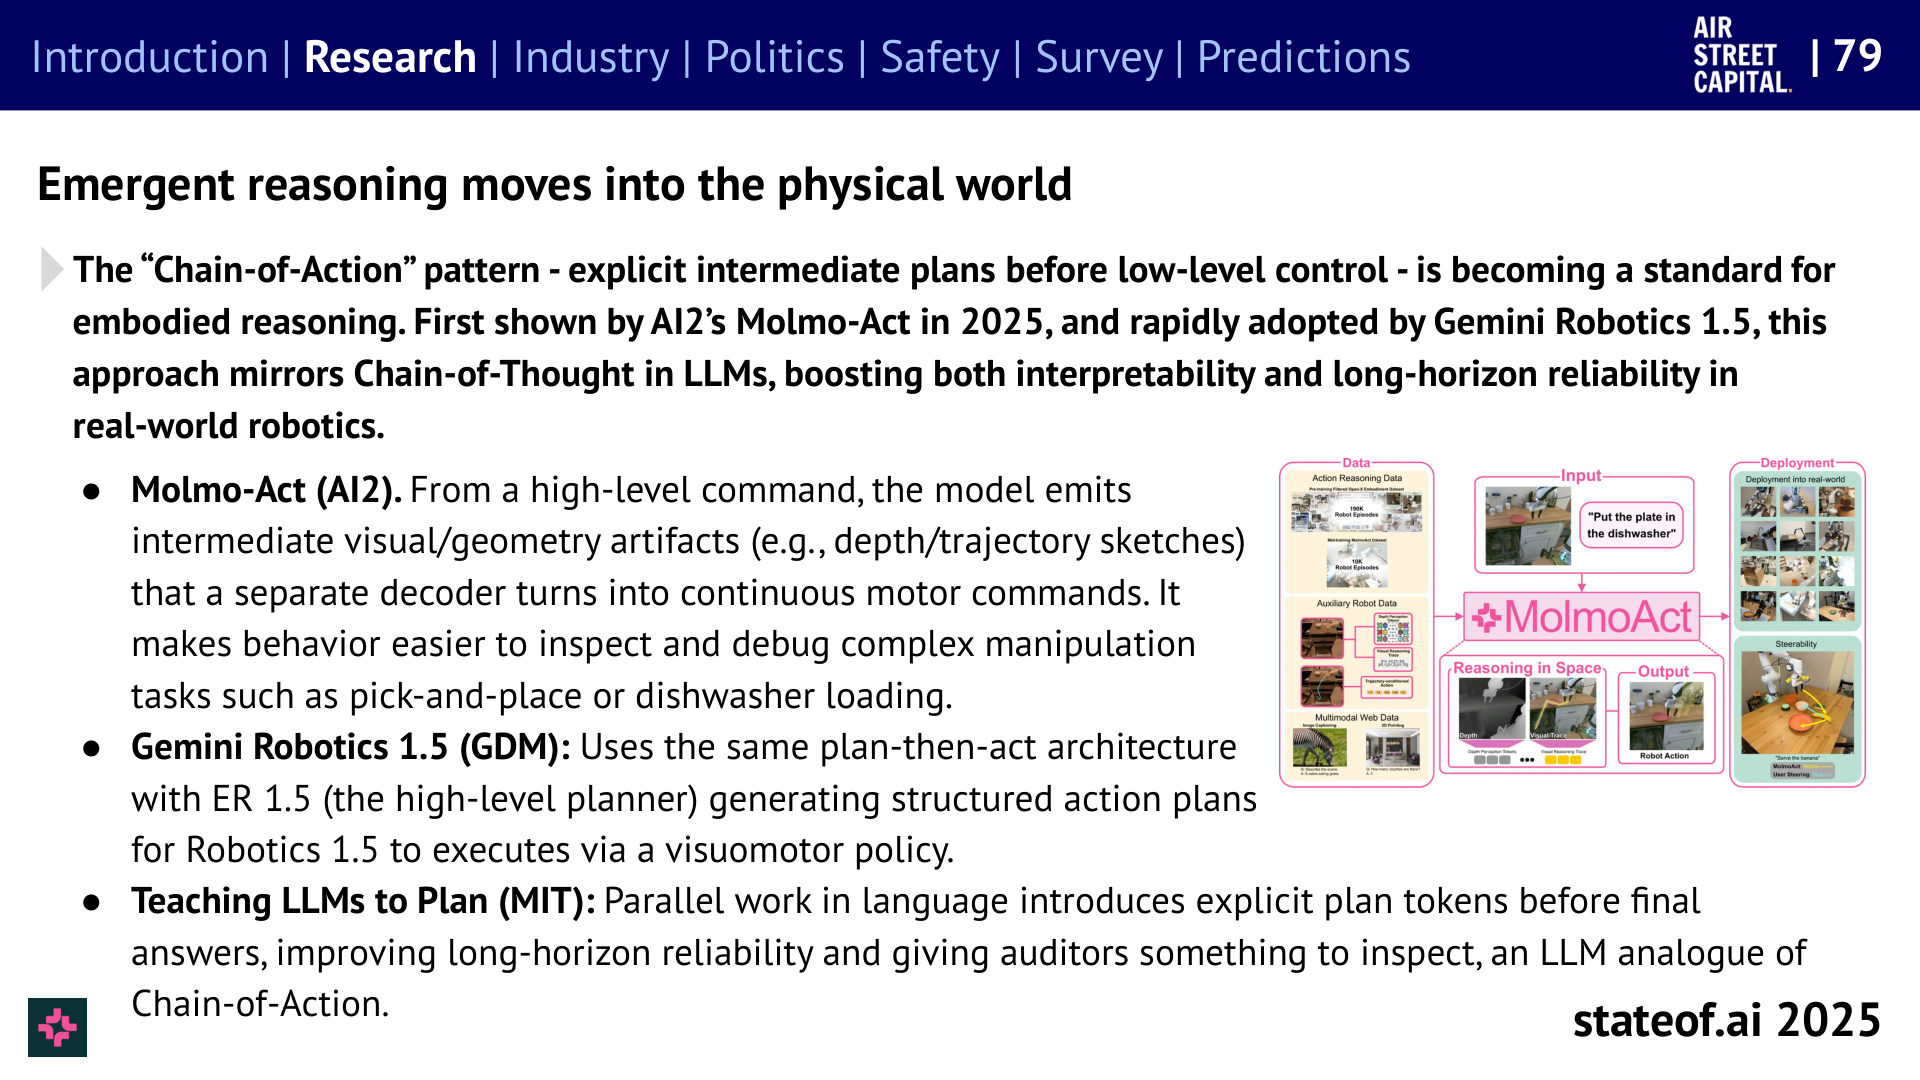
It places explicit intermediate plans between a high-level instruction and low-level robot control. In the report’s examples, those plans helped make complex behavior easier to inspect and organize.
This table compares types of evidence, not a common performance benchmark. Driverless mileage does not establish general manipulation ability, and an inspectable action plan does not establish reliable full-task completion.
Evidence you can use
2025 report snapshot
| Measure | Reported value | Definition and source |
|---|---|---|
| Molmo-Act | Plan before control | Intermediate visual and geometric artifacts2025 report, slide 79 (PDF page 80) |
| Waymo | 71 million rider-only miles | Cumulative through March 20252025 report, slide 173 (PDF page 174) |
| Humanoids | Mostly pilots and research purchases | Report assessment of deployment maturity2025 report, slide 174 (PDF page 175) |
This table compares types of evidence, not a common performance benchmark. Driverless mileage does not establish general manipulation ability, and an inspectable action plan does not establish reliable full-task completion.
Historical snapshot published October 9, 2025. This web edition was prepared on October 10, 2026 from the online deck and original launch posts. Findings and forecasts retain their original time frame.
Benaich, Nathan. “What is Chain-of-Action planning?.” State of AI Report 2025. Historical report snapshot; web edition prepared 2026-10-10.